Tags
Language
Tags
October 2026
Su Mo Tu We Th Fr Sa
27 28 29 30 1 2 3
4 5 6 7 8 9 10
11 12 13 14 15 16 17
18 19 20 21 22 23 24
25 26 27 28 29 30 31
    Attention❗ To save your time, in order to download anything on this site, you must be registered 👉 HERE. If you do not have a registration yet, it is better to do it right away. ✌

    ( • )( • ) ( ͡⚆ ͜ʖ ͡⚆ ) (‿ˠ‿)
    SpicyMags.xyz

    Trending now in eBooks & eLearning


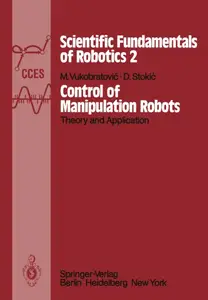
    Control of Manipulation Robots: Theory and Application

    Posted By: AvaxGenius
    Control of Manipulation Robots: Theory and Application

    Control of Manipulation Robots: Theory and Application by Miomir Vukobratović , Dragan Stokić
    English | PDF | 1982 | 379 Pages | ISBN : 3642818595 | 56.4 MB

    This monograph represents the second book of the series entitled: "SCI­ ENTIFIC FUNDAl-1ENTALS OF ROBOTICS". While the first volume provides a study of the dynamics of spatial mechanisms and its application to the design of these mechanisms, the present one focuses on the synthesis -of control based~n the knowledge of dynamic models (presented in de­ tail in the first_ volume). In this way a logical continuity is formed in which one may easily recognize a "dynamic" approach to the design of manipulation r-obots and the synthesis of control algorithms based on exact mathematical models of dynamics of open spatial mechanisms. When writing the monograph, the authors had the following objective: to prove that a study of dynamic properties of manipulation mechanisms is justifiable, to use the dynamic properties in the synthesis of con­ trol algorithms, and to determine, from one case to another, a proper measure of dynamics depending on the type of manipulation task, the "v$!locity at which "it is carried out, and on the type of the manipu- tion mechanisms itself. The authors believe they have thus made the study of dynamics,' aimed at synthesizing algorithms for dynamic con­ trol, free from unnecessary academicism and allowed the readers to apply all the results presented here to practical purposes of manipu­ lator design in thfil broader sense of the word. At this point, the au­ thors would like to present some concepts which were their guidelines in preparing this text.
    Applied Control of Manipulation Robots: Analysis, Synthesis and Exercises

    Posted By: AvaxGenius
    Applied Control of Manipulation Robots: Analysis, Synthesis and Exercises

    Applied Control of Manipulation Robots: Analysis, Synthesis and Exercises by Miomir Vukobratović , Dragan Stokić
    English | PDF | 1989 | 488 Pages | ISBN : 3642838715 | 45.1 MB

    The first book of the new, textbook series, entitled Applied Dynamics of Manipulation Robots: Modelling, Analysis and Examples, by M. Vukobratovic, published by Springer-Verlag (1989) was devoted to the problems of dynamic models and dynamic analysis of robots. The present book, the second in the series, is concerned with the problems of the robot control. In conceiving this textbook, several dillemas arouse. The main issue was the question on what should be incorporated in a textbook on such a complex subject. Namely, the robot control comprises a wide range of topics related to various aspects of robotics, starting from the syn­ thesis of the lowest, executive, control level, through the synthesis of trajectories (which is mainly related to kinematic models of robots) and various algorithms for solving the problem of task and robot moti­ on planning (including the solving of the problems by the methods of artificial intelligence) to the aspects of processing the data obtai­ ned from sensors. The robot control is closely related to the robot pro­ gramming (i. e. the development of highly-specialized programming lan­ guages for robot programming). Besides, numerous aspects of the con­ trol realization should be included here. It is obvious that all these aspects of control cannot be treated in detail in the frame of a text­ book.

    Applied Dynamics and CAD of Manipulation Robots

    Posted By: AvaxGenius
    Applied Dynamics and CAD of Manipulation Robots

    Applied Dynamics and CAD of Manipulation Robots by Miomir Vukobratović , Veljko Potkonjak
    English | PDF | 1985 | 318 Pages | ISBN : 3642822061 | 17.1 MB

    This book is a logical continuation of Volume 1 of the series entitled "Scientific Fundamentals of Robotics" which presents all of the basic methods for computerized construction of dynamics of manipulation ro­ bots as well as the essential concepts of computer-aided design of their mechanics. Vol. 1 of the Series also contains the main practical re­ sults from the elastodynamics of manipulation robots, having in mind a need for forming a computer procedure which allows efficient checks of elastic deformations of a manipulator tip or some other of its charac­ teristic points. Wishing to add a highly applications-oriented dimension to the dynamic aspect of studies of manipulation robots, the authors have made a kind of a topic-based selection by leaving unconsidered some aspects of studies of robots, such as elasticity, and discussing others, more im­ portant in their opinion, to such an extent as suffices to make them practically applicable. The authors have decided not to treat in detail the problem of flexible manipulation robots for two reasons. The first results from the atti­ tude that the permissible (desired) robot elasticity may, satisfacto­ rily well, be tested using the method described in Vol. 1 of the Series.

    Applied Dynamics of Manipulation Robots: Modelling, Analysis and Examples

    Posted By: AvaxGenius
    Applied Dynamics of Manipulation Robots: Modelling, Analysis and Examples

    Applied Dynamics of Manipulation Robots: Modelling, Analysis and Examples by Miomir Vukobratović
    English | PDF | 1989 | 487 Pages | ISBN : 3642838685 | 39.9 MB

    During the period 1982-1985, six books of the series: Scientific Fun­ damentals of Robotics were published by Springer-Verlag. In chronolo­ gical order these were: Dynamics of Manipulation Robots: Theory and Application, by M. Vukobra­ tovic and V. Potkonjak, Control of Manipulation Robots: Theory and Ap­ plication, by M. vukobratovic and D. Stokic, Kinematics and Trajectory Synthesis of Manipulation Robots, by M. Vukobratovic and H. Kircanski, Real-Time Dynamics of Hanipulation Robots by M. Vukobratovic and N. Kircanski, Non-Adaptive and Adaptive Control of Manipulation Robots, by M. Vukobratovic, D. Stokic and N. Kircanski and Computer-Aided De­ sign and Applied Dynamics of Manipulation Robots, by M. Vukobratovic and V. Potkonjak. Within the series, during 1989, two monographs dealing with new sub­ jects will be published. So far, amongst the published monographs, Vol. 1 has been translated into Japanese, Volumes 2 and 5 into Russian, and Volumes 1-6 will appear in Chinese and Hungarian. In the author's opinion, the afore mentioned monographs, in principle, cover with sufficient breadth, the topics devoted to the design of ro­ bots and their control systems, at the level of post-graduate study in robotics. However, if this material was also to apply to the study of robotics at under-graduate level, it would have to be modified so as to obtain the character of a textbook. With this in mind, it must be noted that the subject matter contained in the text cannot be simpli­ fied but can only be elaborated in more detail.